Sept 2026 - Present
Drivetrain Team Member
 UBC Formula Electric
On the drivetrain sub-team for UBC's Formula SAE electric race car, which the team designs, builds and races each year.
Vancouver, BC
Mechanical & mechatronics engineering @
 UBC.
I like building cool stuff with cool people.
Currently into robotics, physical ai, mechanical design, and anything that challenges me.
 SolidWorks
 Revit
 AutoCAD
 CADmep
 Python
 C / C++
 MATLAB
 Arduino
 FEA
 3D Printing
 Git / GitHub
 CSWP: Certified SolidWorks Professional
Dassault Systèmes · advanced part modelling, configurations, and design changes.
View credential →
 CSWA: Certified SolidWorks Associate
Dassault Systèmes · part modelling, assemblies, and drawing fundamentals.
View credential →
Mechatronics specialization · University of British Columbia
UBC Formula Electric
On the drivetrain sub-team for UBC's Formula SAE electric race car, which the team designs, builds and races each year.
 VETS Group
Four-month internship supporting mechanical engineering work on industrial ventilation, HVAC, and dust collection projects.
 SUBC, UBC Submarine Design Team
Designing and validating 2:1 straight-bevel gearbox components for our human-powered submarine's drivetrain. Cut side plate mass 37% and eliminated slippage on the driving pinion.
A decade of live-action and animated productions, starting at age eight. On pause while I'm at UBC.
Coordinating volunteers, sponsors, and route planning for my community's annual run, contributing to over $50,000 raised for cancer research.
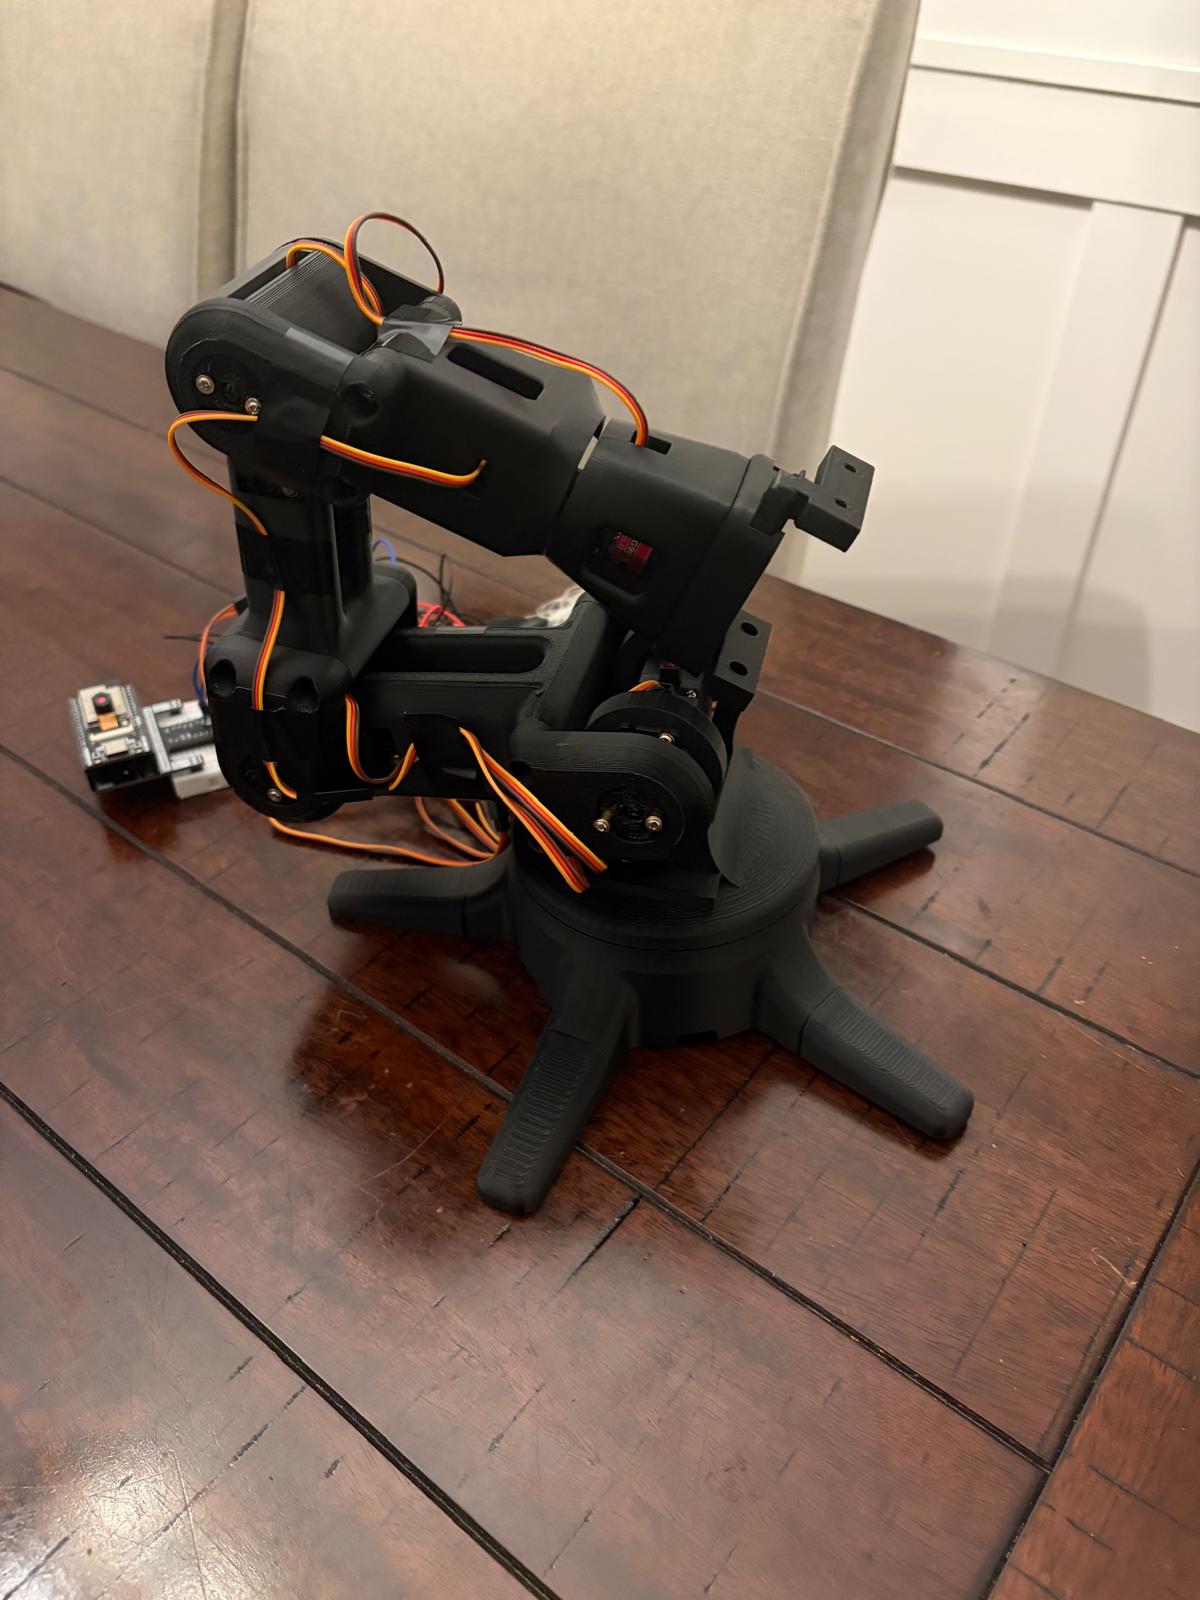
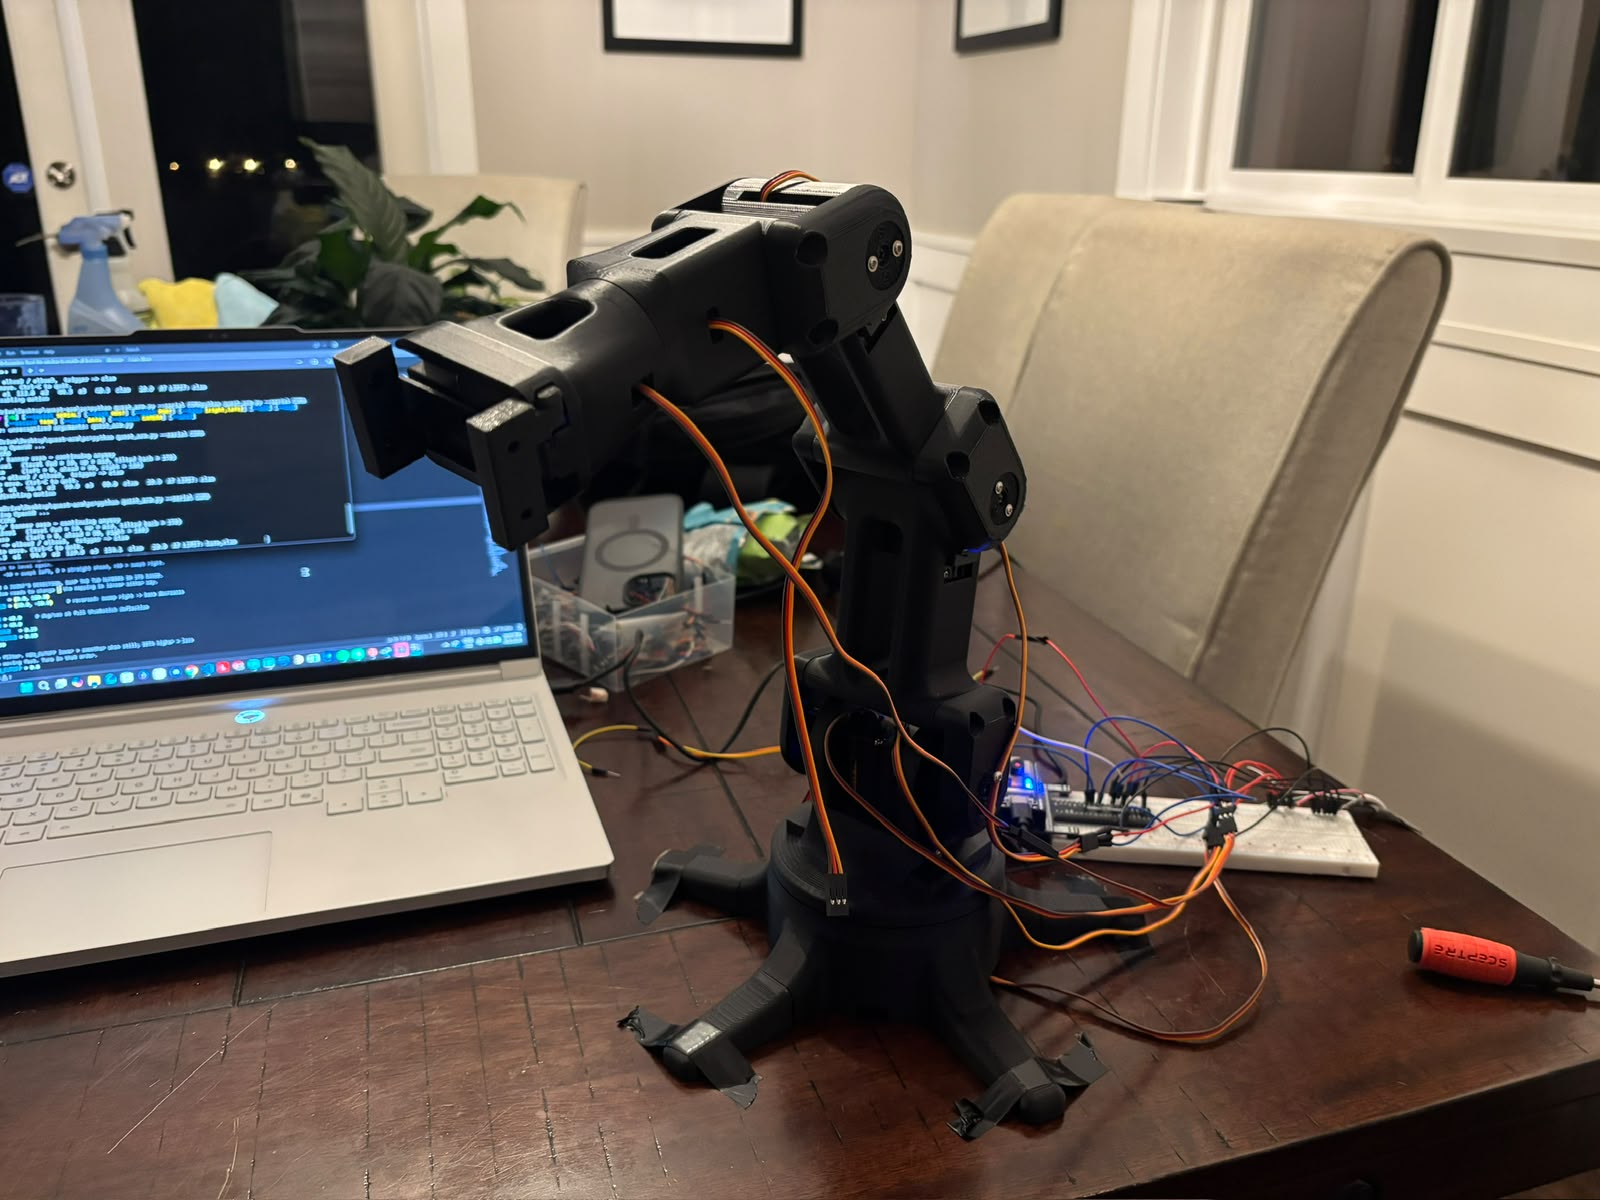
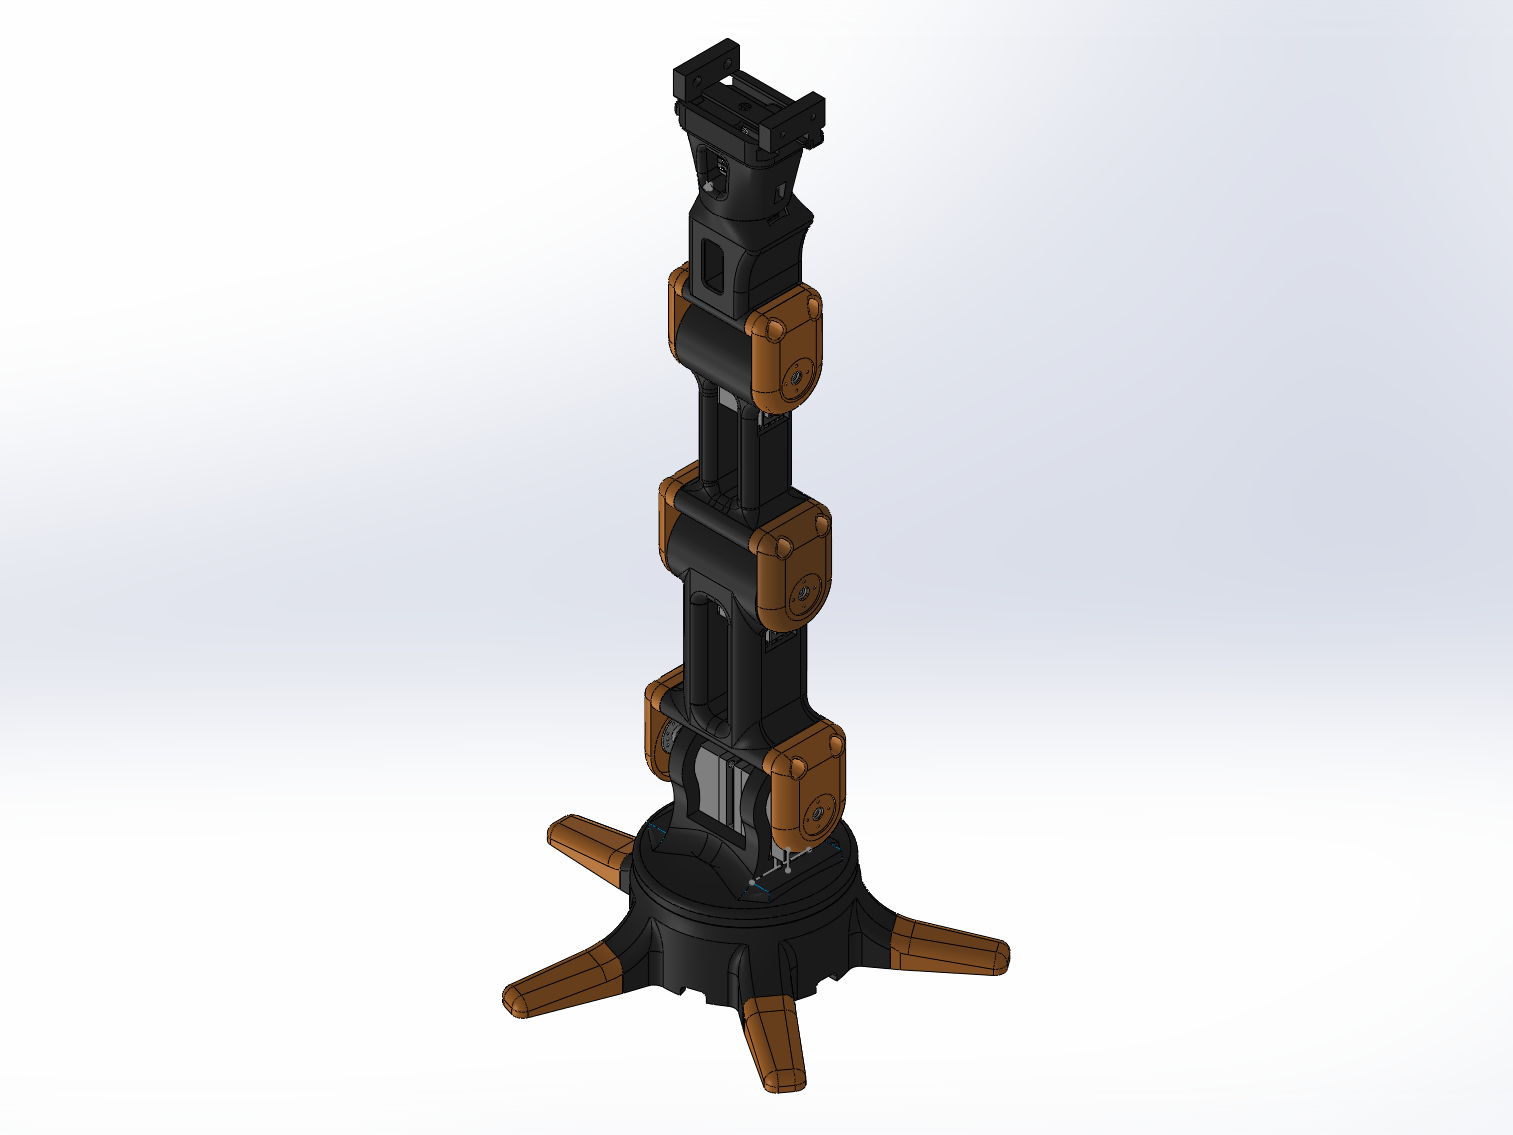
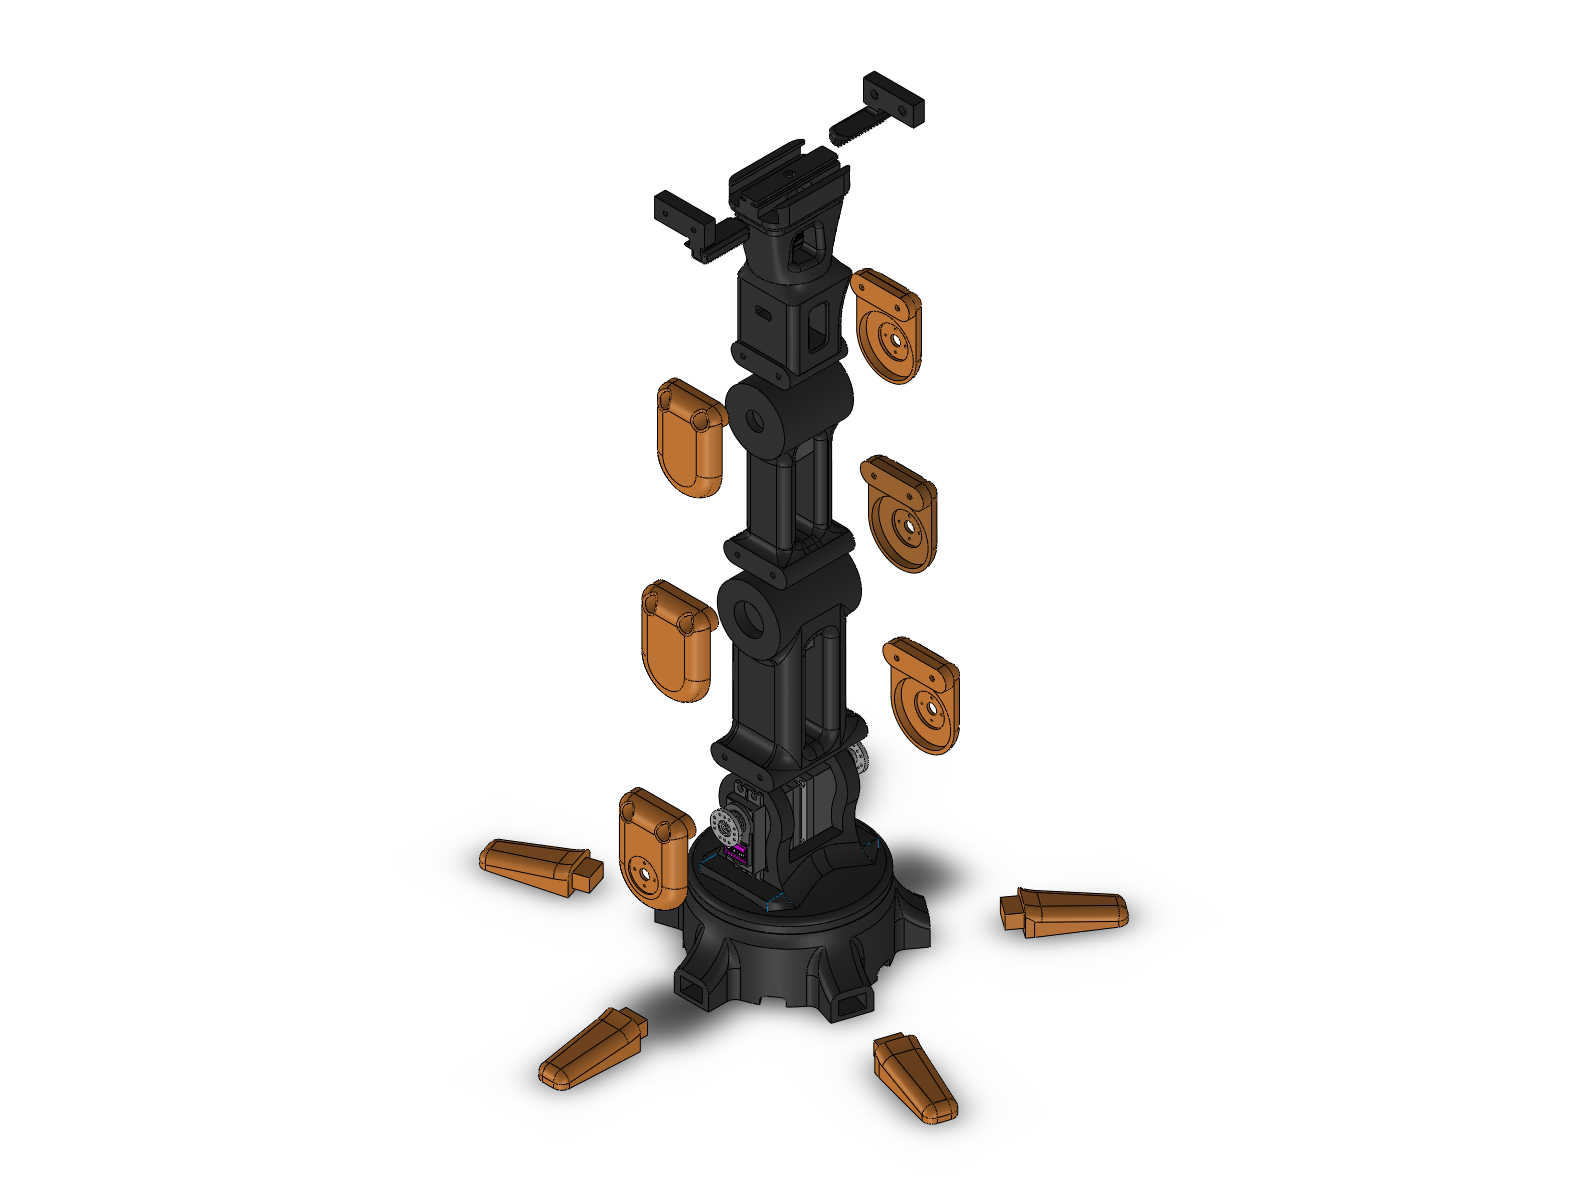
I designed and built the whole arm myself. It's modelled in SolidWorks, every part printed from scratch, no kit involved. I drive it in real time from a VR headset: move your hand, the arm follows.
Each one has its own page with photos, drawings, and a description you can switch between a quick summary and the full technical write-up.
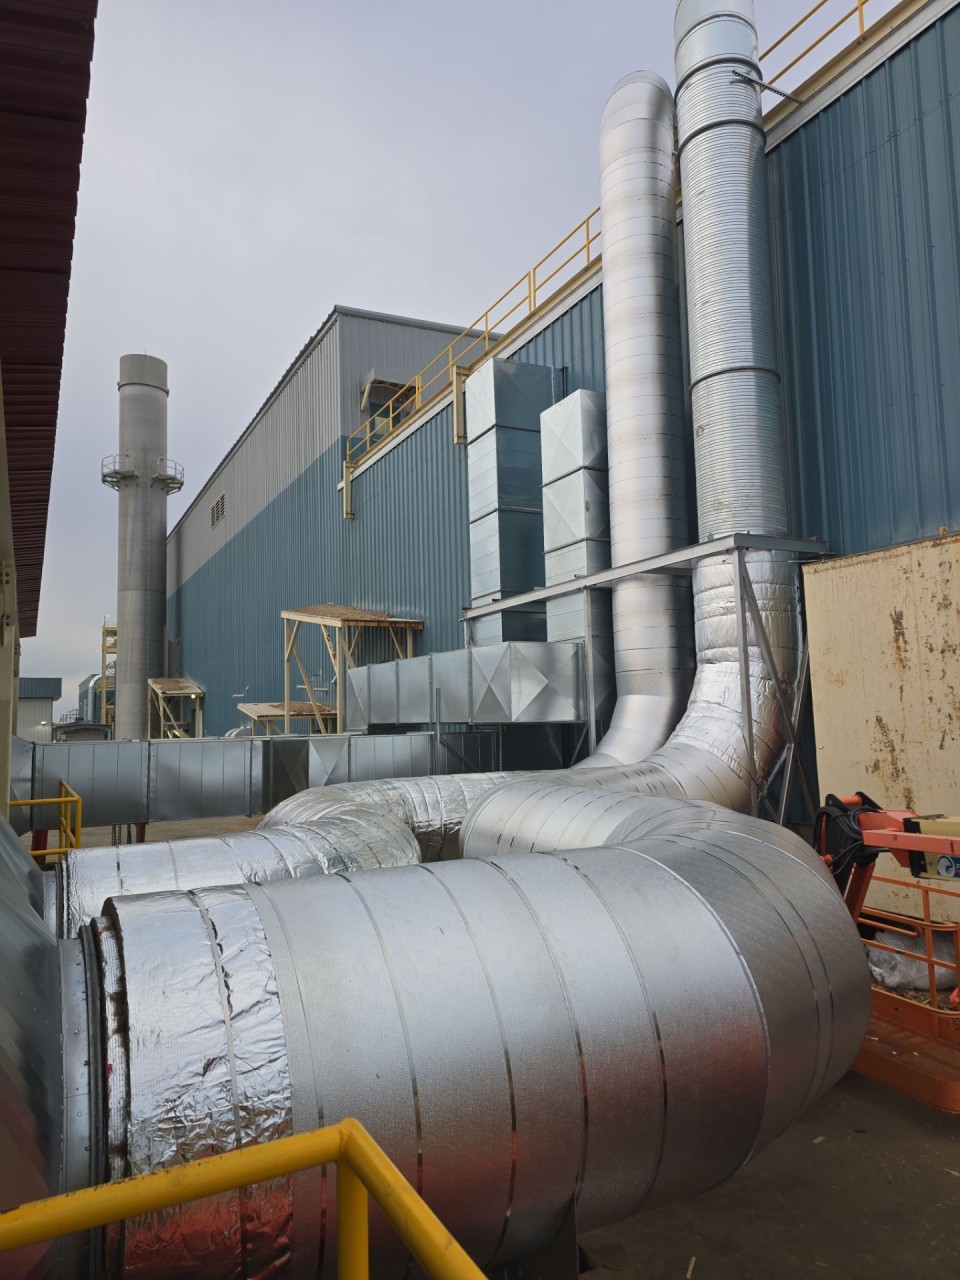
Rerouted the duct for four relocated make-up air units, and designed the towers holding it up.
View project →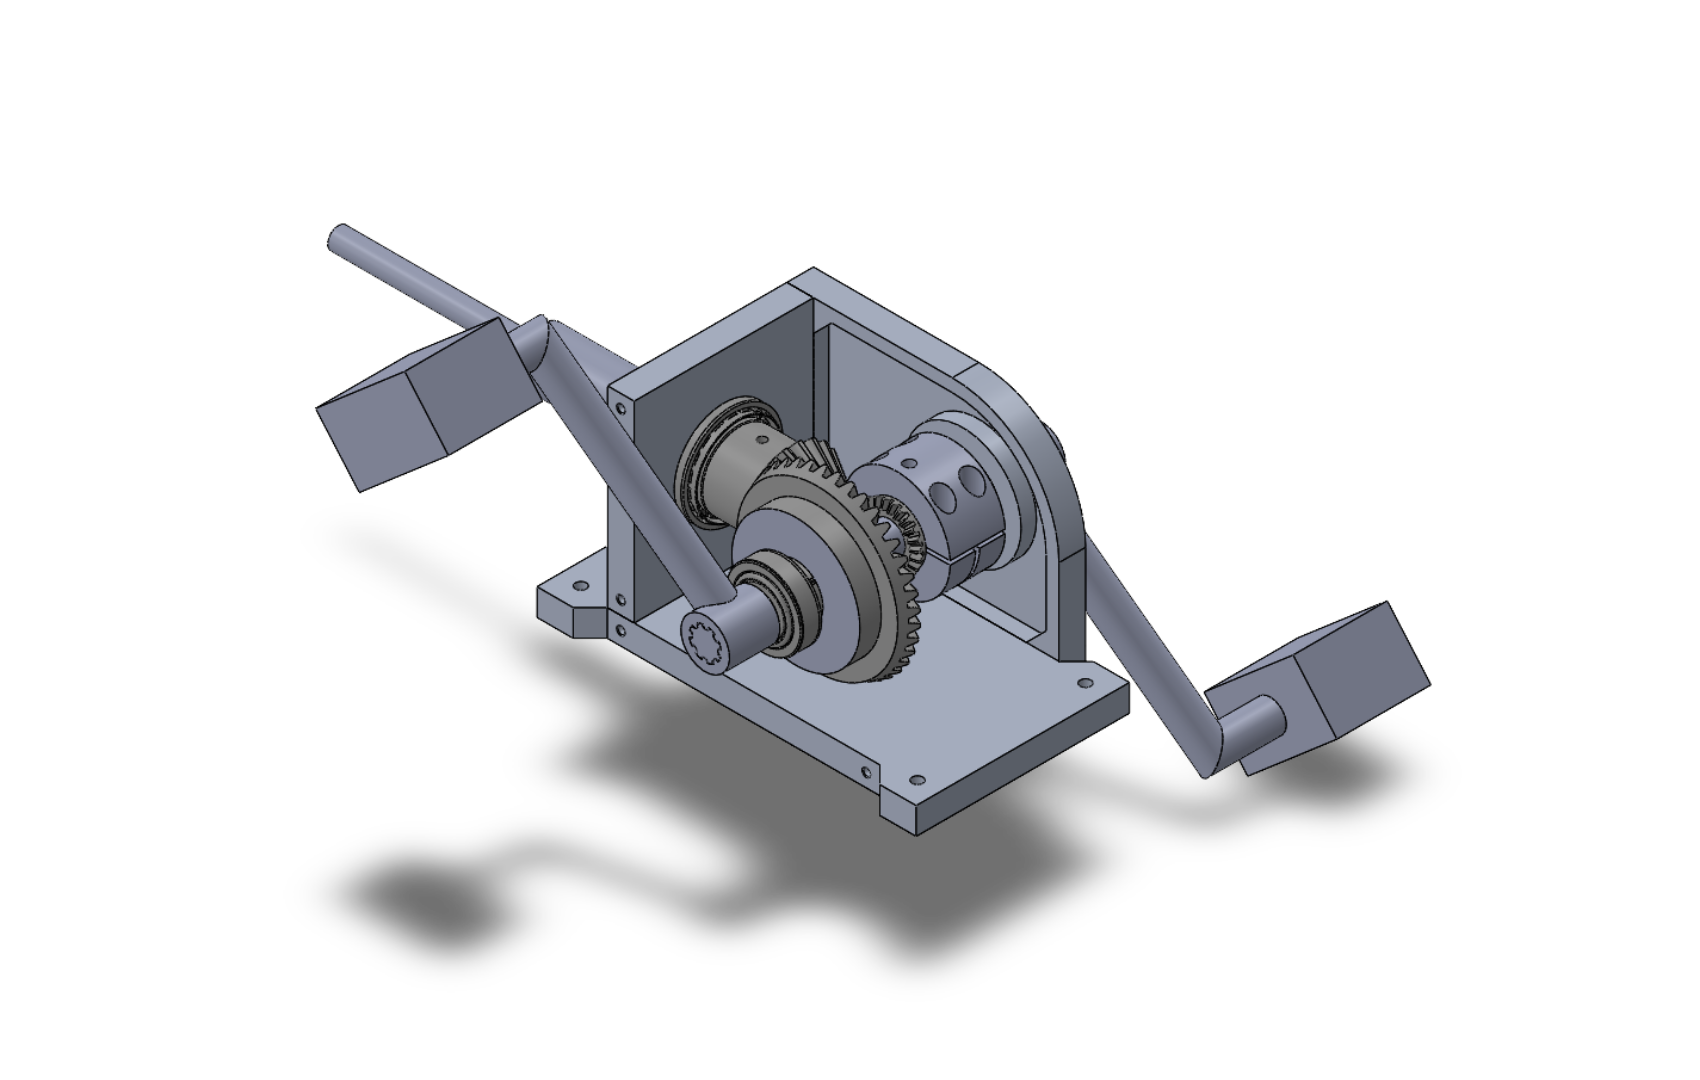
Human-powered drivetrain for UBC's competition submarine. 37% lighter side plates, no more pinion slippage.
View project →
A 5-DOF arm I designed, printed and wired myself, driven in real time from a VR headset.
View project →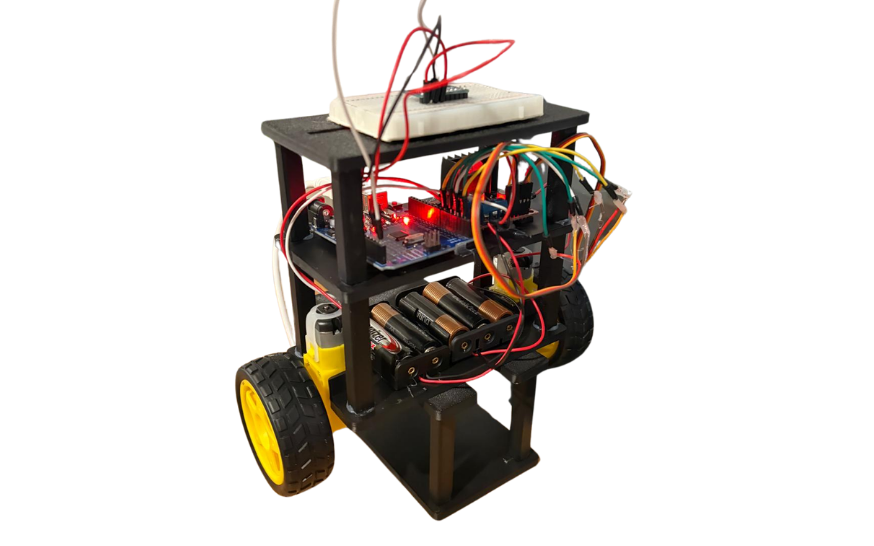
A two-wheel robot that reads its own tilt and drives the wheels to stay upright.
View project →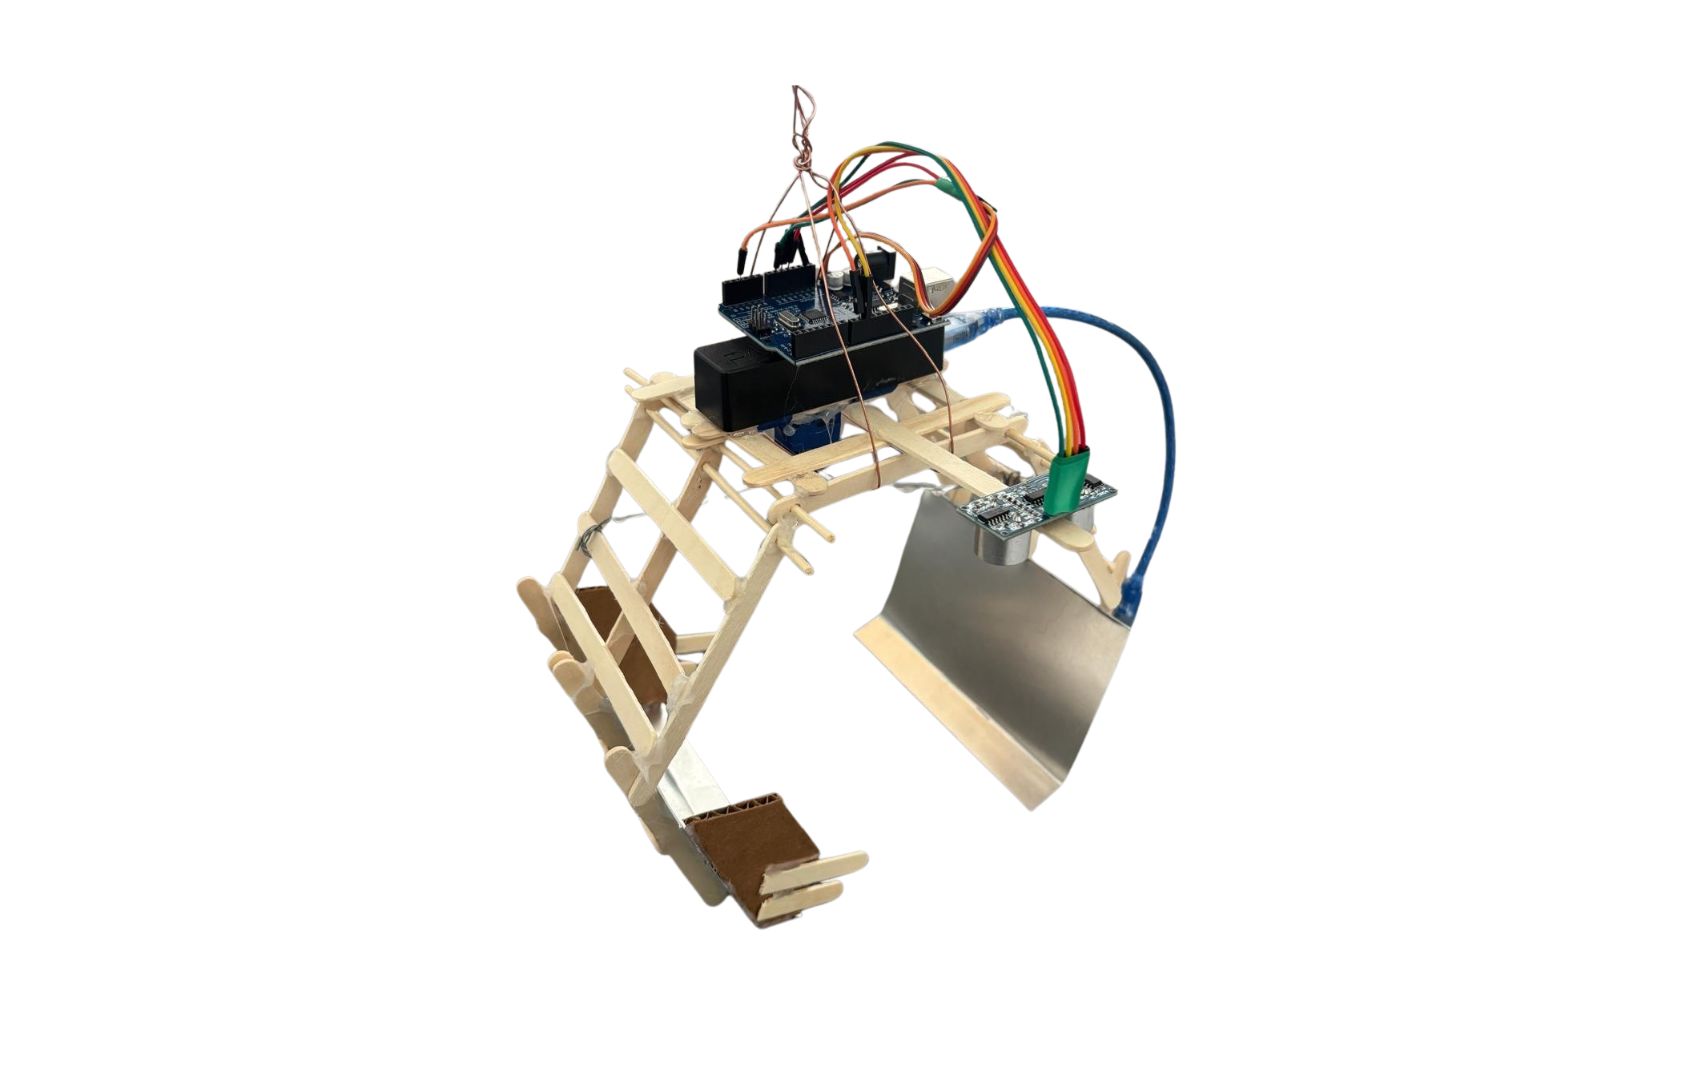
An Arduino claw that senses an object's distance and grips it without input.
View project →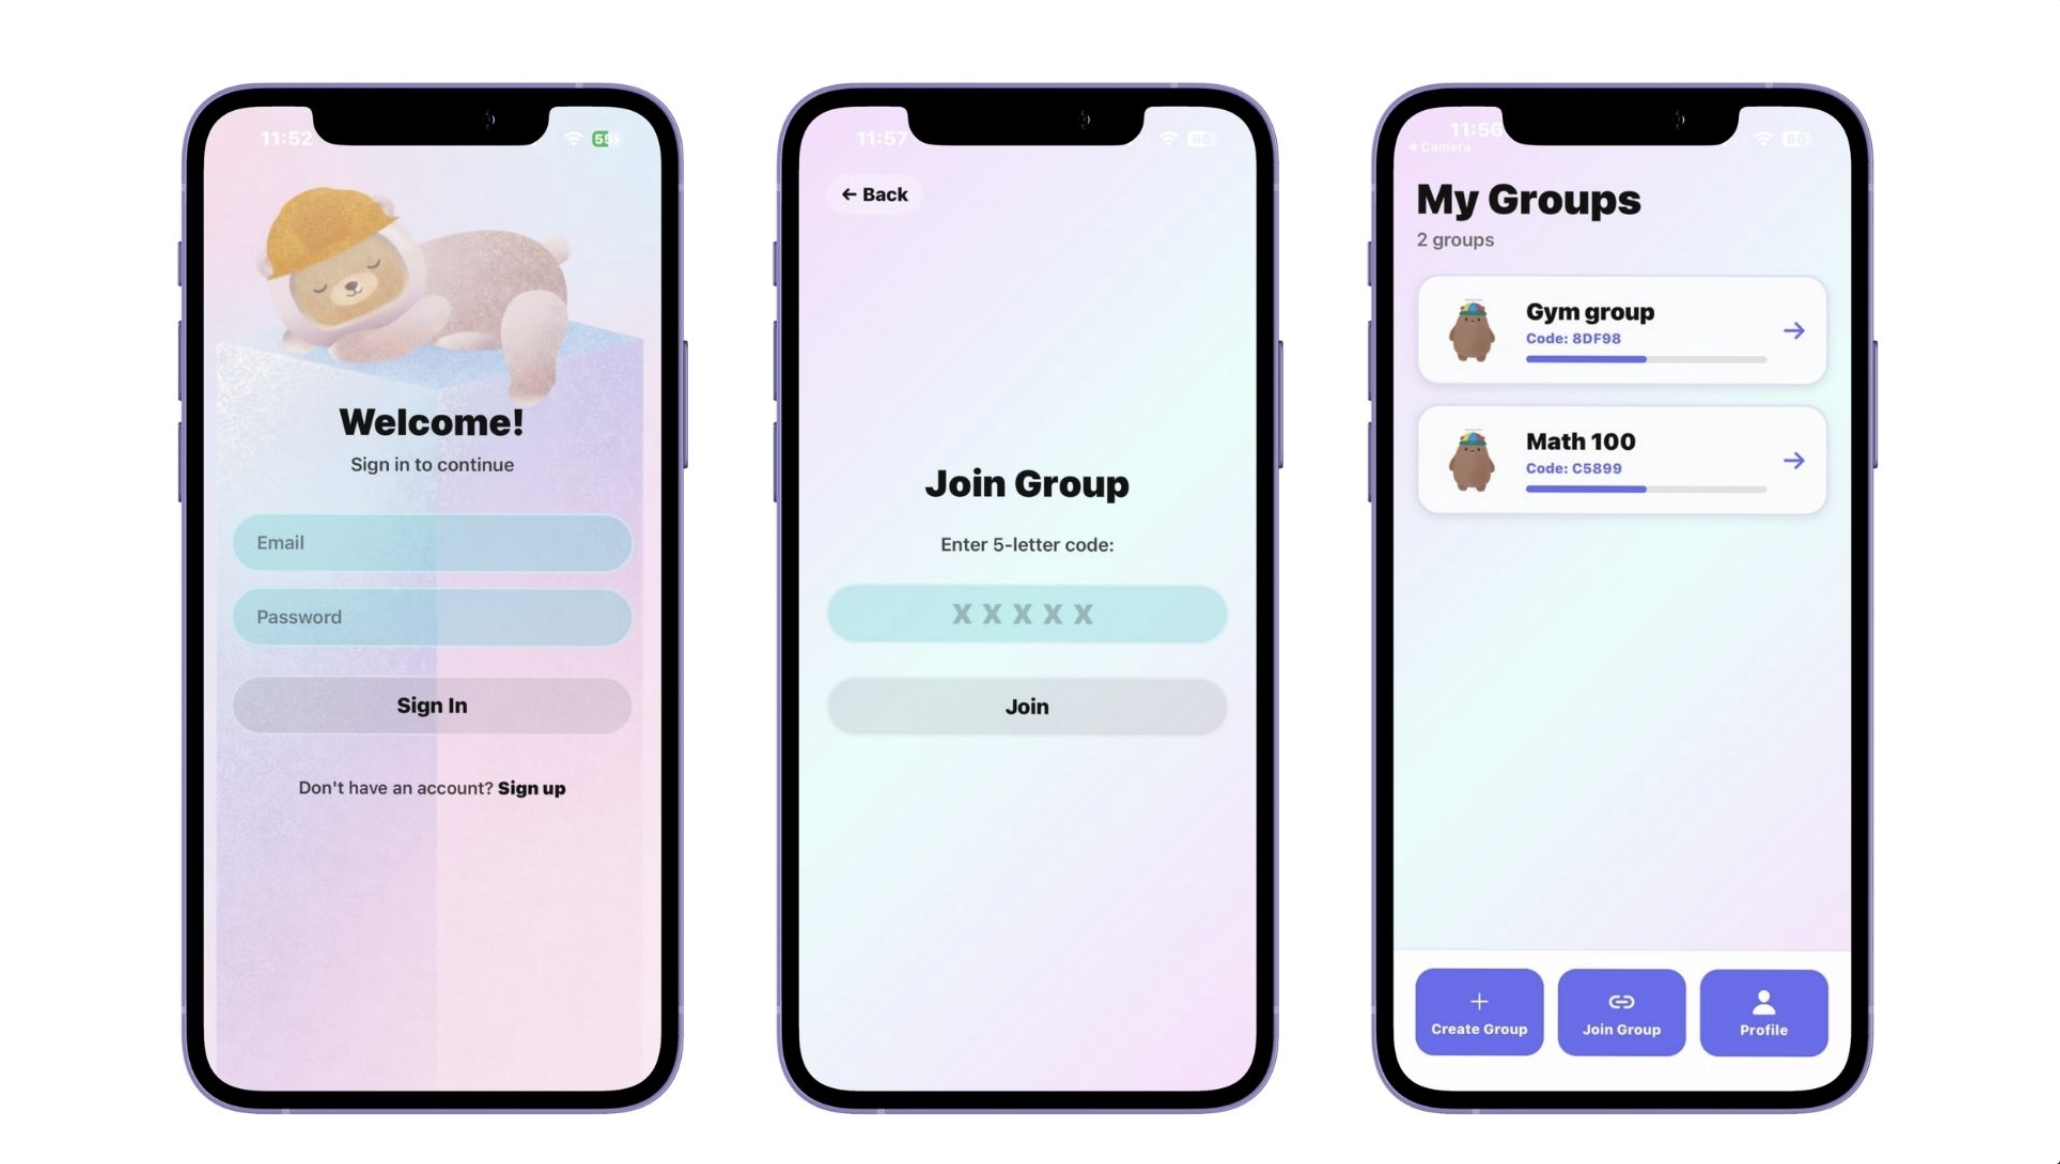
A group accountability app built in 24 hours on 2 Red Bulls and under an hour of sleep.
View project →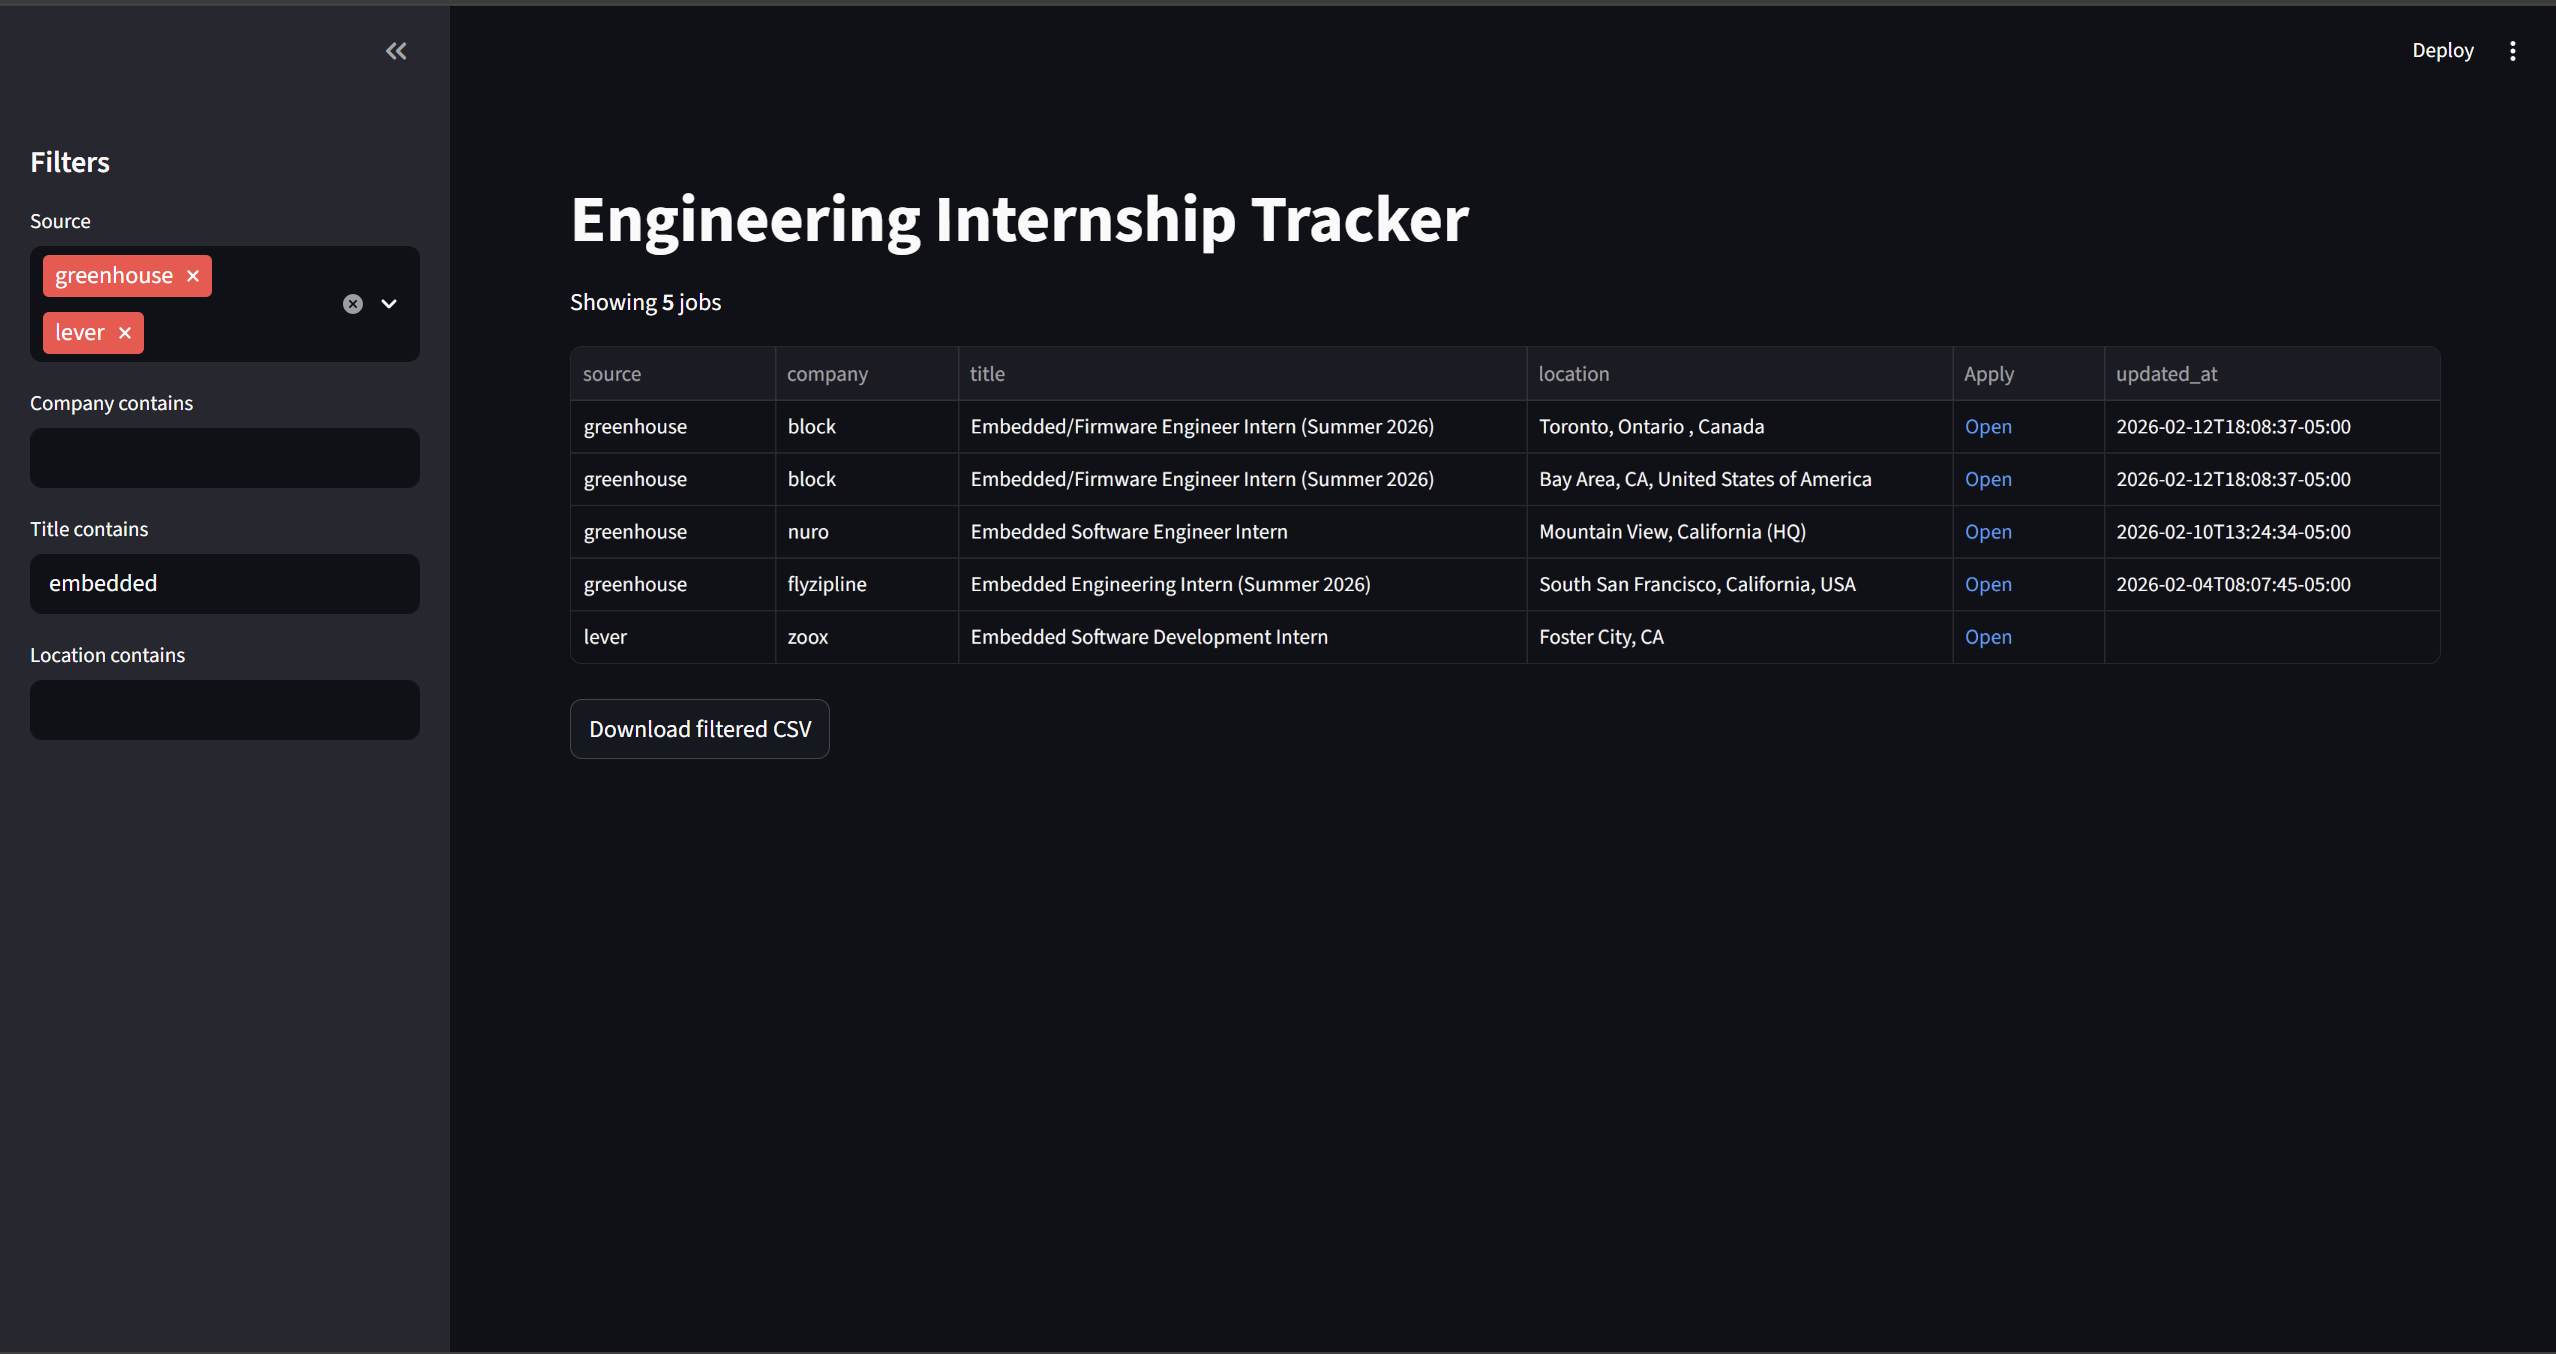
Aggregates postings from the Greenhouse and Lever APIs into one filterable dashboard.
View project →Want to talk about new ideas, engineering, sports, or literally anything else? I'm always up for it.